Practice Makes Precise: At CoRL, NVIDIA and Partners Reveal How Robots Rehearse Delicate Work in Simulation
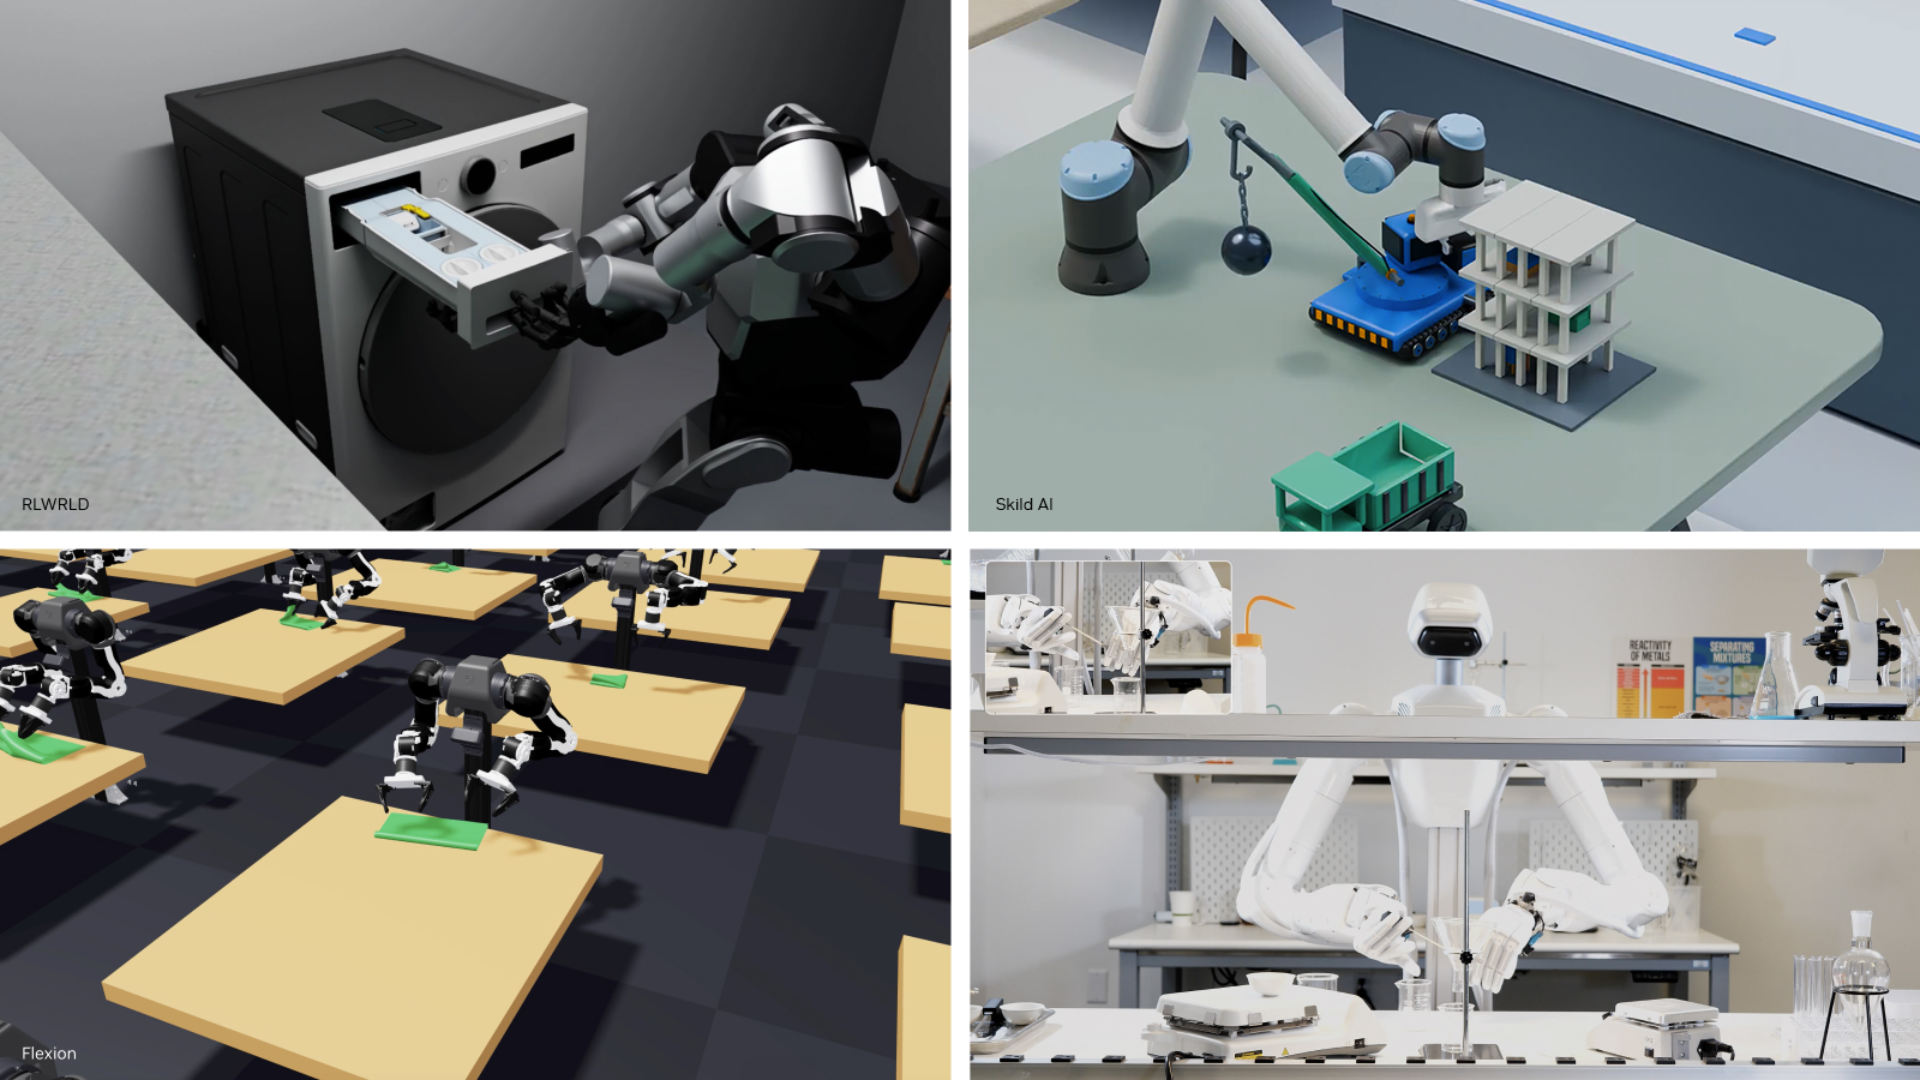
Simulation, which has long been the proving ground for robots learning to walk, roll and hop, is now helping researchers teach robots tasks that require a finer touch: aligning gears, connecting cables and assembling small components.
The shift from locomotion to manipulation is taking center stage at this week’s Conference on Robot Learning (CoRL) in Austin, Texas, alongside the rise of agentic robotics — a new paradigm that integrates frontier agents to create interpretable code for physical robotics systems.
At CoRL, NVIDIA is introducing new open robotics technologies, including world action models, simulation tools, benchmarks and agentic workflows.
Two NVIDIA papers are among six finalists out of thousands of submissions for the Best Paper Awards at CoRL:
GRAIL (Generating Humanoid Loco-Manipulation from World Models), which presents a digital generation pipeline for 3D assets and simulator-ready scenes for robot learning.
RoboTTT: Context Scaling for Robot Policies, which introduces a robot model and training recipe that scales visuomotor context three orders of …
You're reading a preview. The full article is published by NVIDIA Blog on their website.
Read the full story on NVIDIA Blog